Open Master's Thesis Positions
On this page you will find a selection of possible Master Thesis opportunities, some notified to us directly by the research groups of MEST Tutors and some listed on the SiROP database.
This list is not exhaustive, other Thesis projects might exist, please check the respective listings of Departments and research groups you are particularly interested in.
See also Internship opportunities.
Projects directly supplied by MEST Tutors
Master projects:
- Exploring global vs. local learning of products to inform smarter innovation policy at the Energy and Technology Policy Group
Projects from the SiROP Database
ETH Zurich uses SiROP to publish and search scientific projects. Here is a selection of projects currently available which may be suitable for MEST students. For more information visit external page sirop.org.
Functional Incentives for Frequency Reserves: Self-Selection, Attribution, and Strategic Interaction
 Frequency reserves are procured through markets that require firm capacity commitments, which keeps assets with uncertain availability, such as wind, solar and flexible demand, on the sidelines. Functional incentives offer an alternative: the system operator fixes a payment rule that rewards delivered frequency support, and self-interested providers respond to it voluntarily. So far, the theory covers a single provider. This thesis extends it to many providers that act on, and are paid on, the same frequency. It asks which assets self-select into the scheme rather than the reserve market, how a shared improvement should be attributed among providers, and how the operator should design the incentive anticipating both.
Show details
Cooperative Multi-Agent Reinforcement Learning for Heterogeneous Drone Fleets
 Drone fleets are increasingly being deployed for commercial package delivery, with real-world applications involving heterogeneous teams of drones that differ in their dynamics and payload capacities. Multi-agent reinforcement learning (MARL) offers a promising approach to coordinating such teams, but existing methods predominantly focus on homogeneous agents or require policies tailored to different drone types, limiting scalability and transferability. This thesis investigates a layered control architecture for scalable cooperation in heterogeneous drone fleets. The key idea is to decouple cooperative planning from drone-specific execution: the higher layer uses a shared MARL policy to coordinate the fleet and assign delivery tasks, while the lower layer employs drone-specific controllers to track the assigned flight trajectories, accounting for heterogeneous dynamics and ensuring reliable execution with formal performance guarantees. The proposed architecture will be implemented and evaluated in simulation on a heterogeneous drone delivery task, with a focus on scalability, robustness, and transfer to previously unseen drone types.
Show details
Functional Incentives for Sustainable Groundwater Management
 Groundwater is being pumped faster than it is replenished in many regions, causing low river flows, ecosystem damage, and land subsidence. Traditional management restricts or taxes pumping and must be revised whenever conditions change, which is slow compared with how quickly users react. Functional incentives offer an alternative: the manager fixes in advance a payment rule that depends on the aquifer state and each user's pumping, so self-interested users close a feedback loop through their own decisions. This project models a simplified aquifer and evaluates whether functional incentives shorten recovery after droughts and improve robustness to climate and economic uncertainty.
Show details
Optimal Race-line Generation for High-performance Autonomous Driving
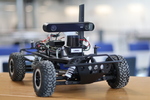 Autonomous driving is a notoriously challenging and safety-critical application in modern control engineering, requiring real-time decision-making, robust performance under uncertainty, and adherence to stringent safety constraints. While Model Predictive Control (MPC) serves as a good controller for this application, practical implementations often rely on simplified models and short horizons, leading to suboptimal performance. This project aims to develop a hyperparameter tuning scheme that optimizes MPC parameters, while designing race line trajectories that minimize lap times and ensure compliance with safety constraints. The method will be validated in both simulation and tested on an autonomous racing car platform at the Institute for Dynamic Systems and Control (IDSC).
Show details
Integration of robotaxi in Zurich urban mobility
 Robotaxis will soon be deployed in the city of Zurich. The goal of the research is to model the effect the entrance of an autonomous driving-based service will have on urban mobility and identify integration policies to preserve social welfare (no congestion, fair access to service, better connectivity for remote locations, environmental sustainability).
The research is framed within the federal project NCCR Automation
Show details
Master Thesis - AI Tools in Energy Systems Design
 This master thesis project aims to conduct a qualitative study on the usage of AI assistance for the energy systems design workflow. How are these tools used today? What are future risks and opportunities?
Show details
Optimal Test-Time Fine-Tuning of LLMs
 This project studies test-time fine-tuning of LLMs using tools from optimal control and optimal experiment design. The student will compare different algorithms, objectives, and data embedding strategies for the fine-tuning problem. They are encouraged to study this problem both theoretically and experimentally.
Show details
People's preferences-informed design of large-scale renwable energy systems
Energy 2050 is one of the Swiss strategies to shift towards renewable energies.
However, this requires building large-scale plants that often face opposition from local communities.
This leads to appeals and delays that are now threatening the achievement of the national strategy targets.
In this project, the student will develop a methodological and numerical approach to embed people's preferences in the design of a renewable energy system.
This will enable the steering of the system design towards solutions that are both engineering optimal and socially oriented.
Show details
Actuated Robotic End-effector Design for 3D Printing
Current applications of 3D printing are constrained by the inherent trade-off between resolution and efficiency. Increasing resolution for higher print quality requires a small nozzle diameter, while increasing speed to increase the material deposition rate requires a larger diameter. This project aims to continue the development of a robotic end-effector for 3D printing, featuring an actuated nozzle that actively controls extrusion parameters throughout the print. The variable-width nozzle actively controls the size of the extrusion bead, allowing a gradient of resolutions across the print. This will be tested with ceramic 3D printing, with the goal of efficiently fabricating high-performance building components.
Show details
PackingDeformableShapesunderDistortionBudgets: Learn- ing Effective Starting Configurations
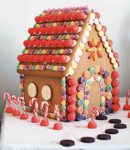 Imagine cutting a gingerbread house from a sheet of dough. Each flat piece (walls, roof, door,...)
has to be cut, and the leftover scraps are wasted. But what if you could change the dimensions of
thehouse? Could you deform the house so that its parts fit onto the dough with much less waste?
Show details
Evaluating the use of thermal indicators for indoor heat stress assessment
 As heat events intensify and become more frequent, concerns about the health impacts of indoor heat stress are growing. Yet, most indoor overheating studies still rely on dry-bulb temperature or comfort indices, with no consensus on which indicators are appropriate and health-relevant in buildings. This project evaluates a small set of candidate indicators for typical Swiss apartments and offices by combining building simulations with selected thermophysiological model outputs.
Show details
Structural Seam Selection: Optimizing Supports in Nearly-Developable Membranes
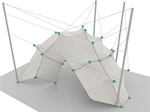 This project extends a method for nearly-developable tensile structures from point anchors to beams, optimizing which seams between fabric patches become rigid, simply shaped beams while keeping the patches flattenable, and validating the results with a physical prototype. For more details please download the full proposal
Show details
Benchmarking Traffic Control Algorithms on Urban and Highway Networks
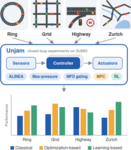 Traffic congestion in densely populated cities keeps worsening, with large costs for commuters,
the environment, and society as a whole. Over the past decades, a wide range of traffic control
strategies has been proposed, from classical feedback controllers to modern learning-based ap-
proaches. However, these methods are typically tested on different networks, demand profiles, and
performance metrics, which makes a fair comparison almost impossible. In this project, we aim at
building a systematic benchmark for traffic control, in which classical and cutting-edge controllers
are implemented and compared on a common set of urban and highway networks under identical
conditions. The benchmark will be built on top of Unjam, a simulation framework developed in our
group that makes closed-loop experiments on SUMO simple, scalable, and reproducible.
Show details
Multi-Agent Reinforcement Learning for RoboCup
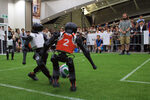 Coordinated positioning is essential for any task carried out by a team of robots. In RoboCup this layer is often hand-designed in every league: the Small Size League champions assign supporter positions through rated candidate locations~\cite{tigers2022}, the Standard Platform League champions position the humanoid robots with Voronoi-based schemes~\cite{bhuman2022}, and the 2D simulation champions rely on triangulation-based formations~\cite{helios2024}. At the other extreme, end-to-end multi-agent reinforcement learning (MARL) can discover positional play on its own~\cite{marladona}, but depends on simulator parameters that may not match the real robots.
To address this problem, this semester project focuses on using explicit and calibrated skills such as go-to-point, intercept, pass and kick, with MARL then learning the appropriate positioning strategy as an upper decision layer. This layer depends on the knowledge of how likely each skill is to succeed, and the project makes these likelihoods explicit, estimates them online, and tests whether a policy conditioned on them transfers to the skill stack of the Booster robots.
Show details
Verifiable Control Design with Data-Driven Spectral Submanifolds
 Low-dimensional latent space representations of dynamical systems provide a powerful tool for scalable control design. Over the last years, learning-based approaches for constructing latent space representations have gained popularity, often utilizing variational autoencoders. While these approaches have shown great empirical success, they typically lack formal control guarantees as needed in safety-critical applications. In recent work, we presented a framework for designing controllers in such learned latent spaces that can provably guarantee stability and safety for the original system by exploiting approximate conjugacy between the latent and full dynamics. However, large approximate conjugacy can result in overly conservative and poorly performing control actions. On the other hand, spectral submanifolds were studied in as attracting invariant manifolds. Spectral submanifolds guarantee the existence of a low-dimensional latent space representation that, if restricted to the manifold, have the same behavior as the original system. Spectral submanifolds are constructed from the linear components of a dynamical system and have zero conjugacy error, even though their data-driven construction is approximate in nature. This thesis will investigate how to integrate the framework of spectral submanifolds into the latent space control design framework from \cite{lutkus2025latent} to achieve non-conservative control behavior while retaining stability and safety guarantees. The project combines insights from dynamical systems, control theory, and data-driven reduced order models.
Show details
Probabilistically Safe Motion Planning in Uncertain Dynamic Environments
 Autonomous robots operating in dynamic environments must plan around obstacles with uncertain future trajectories, such as pedestrians or vehicles. Existing motion planning approaches either ignore this uncertainty—risking collisions—or rely on heuristic safety margins, leading to overly conservative behavior without formal guarantees.
This work establishes a principled, data-driven framework that integrates conformal prediction with the augmented Graph of Convex Sets (GCS) motion planning paradigm. The key insight is that the H-representation of obstacles in spacetime GCS naturally aligns with conformal prediction sets. By scaling the polytope constraints using conformal quantiles calibrated from trajectory data, we construct spacetime uncertainty sets with finite-sample coverage guarantees.
Coupling these probabilistically certified sets with deterministic GCS planning yields end-to-end safety guarantees: the probability of collision is bounded by a user-specified risk level. This approach enables tunable, statistically grounded safety in motion planning under uncertainty.
Show details
Decentralized Damping Guarantees for Converter-Dominated Power Systems
 This project investigates how local conditions on converters and network lines can guarantee adequate damping of oscillations in power systems. Building on recent semidefinite programming methods for decentralized stability certification, it will explore certificates for prescribed minimum damping ratios and decay rates. The aim is to enable independent component verification without repeating a system-wide study whenever an admissible component is connected or replaced.
Show details
Thermal and Structural Analysis of 3DP Building Components
Additive manufacturing has shown great potential in the building industry, enabling the fabrication of complex, customisable geometries that were previously impossible with conventional fabrication. Combining the advancement of this technology with ceramics, a fundamental building material with exceptional properties of durability, thermal stability and strength, functional properties of building components can be enhanced. This research investigates the potential of optimising the thermal and structural properties of ceramic 3D-printed components through a parametric design workflow that explores parameters of form, thickness and infill geometry.
Show details
Understand the Game: Building a Digital Twin for Swissgrid's Voltage Support Program
 Swissgrid keeps transmission grid voltages within limits through a voltage support program, in which power plants and distribution system operators (DSOs) decide autonomously how much reactive power to provide, based on remuneration and penalties. Operational data show that participants respond to these incentives in very different ways, and this strategic behavior is not correctly represented when Swissgrid computes the voltage references. In this master thesis, you will build a digital twin of the program that predicts the reactive power of all participants and the resulting grid voltages for a given set of voltage references, using inverse optimization, game-theoretic modeling, and real Swissgrid data.
Show details
EVALUATING OUTDOOR THERMAL COMFORT USING A MIXED-METHOD TO IMPROVE THE ENVIRONMENTAL QUALITY OF THE ETH HÖNGGERBERG CAMPUS
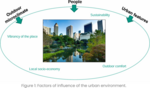 This Master’s thesis investigates outdoor environmental quality and human comfort at the ETH Hönggerberg Campus. The project will combine on-site measurements, user surveys and interviews, environmental simulations, and spatial analysis to identify critical outdoor areas from both environmental and user perspectives.
The student will investigate environmental factors such as solar radiation, air temperature, humidity, wind, surface temperature, sound, air quality, and lighting, and relate them to users’ perceptions and outdoor activities. Based on the findings, the thesis will propose evidence-based retrofit strategies to improve comfort and the quality of outdoor spaces on campus.
The project offers an interdisciplinary opportunity combining urban design, environmental simulation, field measurements, and human-centric research, with tools such as Rhino-Grasshopper, Ladybug Tools, and ClimateStudio.
Show details
DEMOCRATIZING THE DESIGN OF VISUALLY ACCESSIBLE SPACES: DEVELOPMENT OF TOOLS AND THEIR APPLICATION TO EVALUATE ARCHITECTURAL DECISIONS
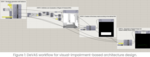 People with low vision often experience difficulties navigating architectural spaces, particularly where steps, corners, and level changes are present. Conventional lighting and architectural design approaches primarily rely on illumination levels and do not fully account for how visual impairment, material properties, lighting, and contrast affect the visibility of potential hazards.
This Master’s thesis will investigate how **indoor materials and artificial lighting systems influence hazard visibility for people with different levels of visual impairment**. The research will build on the DeVAS (Designing Visually Accessible Spaces) workflow and its integration into **Rhino-Grasshopper**, enabling architects and designers to evaluate visual accessibility directly within familiar design environments.
Using a hospital building in Zürich as a case study, the student will conduct simulation-based investigations and evaluate architectural and lighting design alternatives using the **Hazard Visibility Score (HVS)**. The results will contribute to practical guidelines for designing more visually accessible and inclusive indoor environments.
Show details
Biomaterial Development for Ceramic 3D Printing
Clay can be shaped and formed through a wide range of techniques, and a subsequent sintering process transforms it into ceramic, a stiff and durable material well-suited to building components. In Direct Ink Writing (DIW), clay must retain a certain water content to enable extrudability for printing. After printing, the part passes through a drying stage in which water is lost, causing shrinkage, and is then sintered at high temperatures. The shrinkage and warping that occur during drying and sintering introduce dimensional deviations, which are problematic for the tolerances required in building components. Therefore, this research develops an organic composite paste to be co-extruded during the 3D-printing process, which aims to reduce the drying and sintering shrinkage of the resultant ceramic component.
Show details
Development of a Point Cloud Encoder for Force-Aware Manipulation Policy Learning
 Contact-rich manipulation tasks, such as polishing and assembly, are inherently geometric tasks where directional information—such as the insertion axis and local surface normals—is essential. This project focuses on developing a geometry, direction-aware point cloud encoder for policy learning to achieve superior generalization across novel environments and target objects. Conducted in collaboration with Bota Systems AG, this project offers direct exposure to real-world physical AI applications within the modern robotics industry.
Show details
Physics-Informed Multimodal Contact-State Learning for Force-Aware Robotic Manipulation
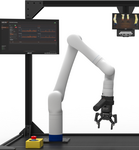 Contact-rich manipulation tasks, such as polishing and assembly, involve complex transitions across multiple states including free-space motion, impact, sliding, sticking, and separation. This project focuses on developing a multimodal transformer that uses rich multi-modal sensor streams including force-torque, vision and robot motion to anticipate contact transitions ahead of time. Conducted in collaboration with Bota Systems AG, this project offers direct exposure to real-world physical AI applications within the modern robotics industry.
Show details
Discover What’s Missing: Mining Environment Assumptions for Robot Manipulation
 Robots can learn to perform surprisingly complex tasks, but a learned policy does not necessarily tell us when it will succeed and when it will fail. In this project, you will test a robot manipulation policy in simulation across many different environment variations and investigate how environmental conditions affect its behaviour.
The goal is to discover where the robot can be trusted — for example, which combinations of object properties, friction, placement, or clutter lead to reliable behaviour — and turn these findings into a simple, human-readable description of the robot’s operating conditions. For this, we will use formal languages such as signal temporal logic, which are widely used to establish formal guarantees for intelligent systems.
The project combines robot learning, simulation, and safety, with a strong focus on exploring the environment efficiently and understanding the failures of learned policies.
Show details
Decentralized Grid-Equivalent Model Identification
With the increase in sustainability concerns and ”net-zero” initiatives, the power grid is gradually being
replaced with renewable energy sources and power electronic technologies (PETs). However, the
integration of PETs into the grid comes with several challenges, in particular, with data-driven modeling,
control, and stability analysis of the grid. To this end, grid impedance models have been very useful, for
example, aiding in ascertaining small-signal stability, enabling adaptive control to ensure stability, and
ensuring the safety of distributed generation systems by identifying islanding conditions.
To identify the grid impedance, we normally consider a ”small-signal model”, i.e., a linearized
transfer function that represents the equivalent impedance relating the terminal voltages as inputs and
current injected at points of common coupling (PCCs) as outputs. For a large-scale power grid, the
identification via a centralized approach presents many challenges: synchronizing time steps owing to
different operating time-scales of various sources and loads, and of course scalability.
Thus, in this project, we would like to develop a decentralized grid-equivalent identification algorithm
in the time domain.
Show details